 JAX Pathways
Phase 10 / Scientific computing
Vectorize trajectories and scan time
Revision v0.7.0 · Updated since your last visit. Review the changes; your progress is saved.
Lesson · about 100 minutes · CPU practice
Construct and verify a fourth-order fixed-step transition. Distinguish batch-major from time-major trajectory layouts.
Phase study guide: preparation, milestones and project evidence
Before you start
Before this: A functional physical simulation
Hardware: CPU
Setup help: Python, notebook, or Cloud TPU VM
Use the tested CPU packages (the recorded environment uses Python 3.14.3). Other Python versions and accelerator environments require separate checks. The optional Cloud TPU specialization explains the target-specific execution boundaries. Logical CPU devices practice partitioning; they do not simulate TPU performance.
Download the repository ZIP or use your existing checkout. Extract it and open a terminal in the folder containing requirements-cpu.txt. The beginner ZIP is separate; these lessons use the full repository folder.
python3 -m venv .venv
source .venv/bin/activate
python -m pip install -r requirements-cpu.txtpy -3 -m venv .venv
.\.venv\Scripts\python.exe -m pip install -r requirements-cpu.txtAfter activation, run the complete worked example from that same folder:
python phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.py.\.venv\Scripts\python.exe phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.pyFor an incremental build, create main.py in your own practice folder, append each build block in order, and run python main.py with this environment active. Keep that file separate from the downloaded reference solution.
Download this lesson’s notebook. Open it with a Python kernel using the course environment. Run cells from the top after restarting the kernel; experiments depend on earlier definitions.
For local Jupyter, first install the course requirements using the Local Python steps, then use your environment’s Python to start Jupyter:
python -m pip install jupyterlab
python -m jupyter lab.\.venv\Scripts\python.exe -m pip install jupyterlab
.\.venv\Scripts\python.exe -m jupyter labSelect the downloaded science-02.ipynb file in JupyterLab. The notebook contains reference solutions; make your prediction and attempt each practice task before opening them. Restart the kernel before changing logical device setup.
The worked reference for this lesson is CPU-validated. Some references explicitly configure logical CPU devices; setting JAX_PLATFORMS does not adapt them to a TPU. Follow the execution matrix and reviewed multi-host example before attempting a target run.
For accelerator preparation, study TPU setup, observed runtime receipts, checkpointed jobs and precision and retained traces. These target paths remain unqualified on physical TPU hardware until an actual receipt is recorded. Cloud provisioning is optional for CPU learning.
Check: Shape (3, 41); endpoints approximately [0.12329849, 0.24659697, 0.49319394]. Both compositions agree.
Revisit the guided CPU setup · Open 19: TPU Setup. Package instructions are CPU instructions; Windows and accelerator environments need their own validation.
What you will be able to do
- Construct and verify a fourth-order fixed-step transition.
- Distinguish batch-major from time-major trajectory layouts.
- Compare two valid scan/vectorization compositions numerically.
- Separate independent ensembles from interacting states.
The problem
You need to simulate a collection of experimental starts, not just one. Which dimension represents independent experiments, and which represents sequential time? We will build both compositions explicitly and verify that their axes and physical predictions agree.
The idea
A simulation ensemble repeats one rule across independent systems and across time. Vectorization handles the independent systems; recurrence handles each system's evolving state. Name those axes before composing transforms.
There are two different axes of repetition
Picture a grid with time running left to right and one independent trajectory per row. State arrows connect adjacent times within a row. No state arrow crosses into another trajectory unless the physical model explicitly couples them.
Initial conditions can vary by trajectory while a physical parameter stays shared, or both may vary. That is an argument-mapping choice, not merely a shape convenience. Record it before applying vectorization.
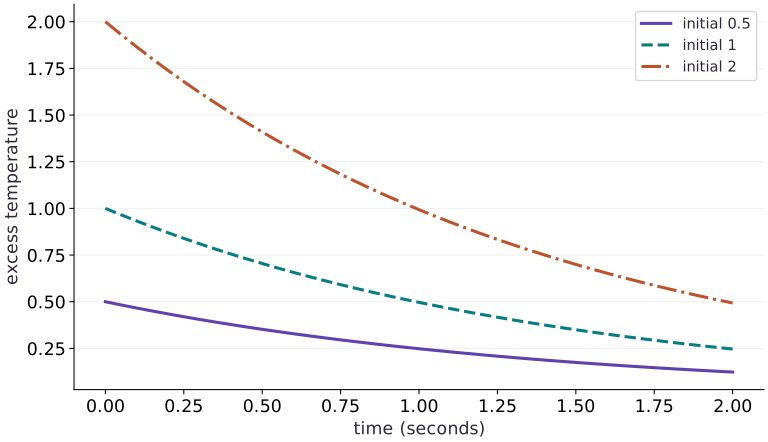
The trajectory plot shows outputs of that grid. Preserve the returned time/batch axis order when plotting; an accidental transpose can connect different systems instead of successive times. Compare one row with an independently run single trajectory.
Vectorize across systems; scan through time
Predict: What should happen if you permute independent initial conditions?
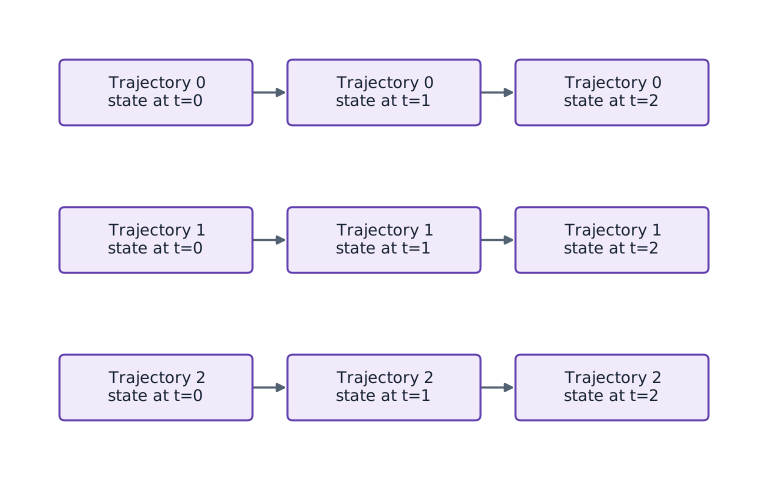
Each row is an independent initial condition. Horizontal arrows advance only that system; there are no cross-row state dependencies. Vectorization groups rows and scan represents recurrence. Boxes show state positions in the computation, not physical coordinates or measured durations.
Improve one step before multiplying trajectories
Forward Euler samples the slope only at the start of the interval. Classical RK4 samples a start slope, two midpoint slopes and an endpoint slope, then combines them with weights . The intermediate states are trial values, not four extra saved observations. For our linear equation the full step is multiplication by a fourth-degree approximation to . This makes an independent algebraic oracle possible.
Read shapes as physical statements
Three initial values and forty updates produce a batch-major array of shape . Row is one trajectory; column holds all experiment values at time . The extra time point is the initial state. We deliberately use different axis sizes to make an accidental transpose visible. A mean over the batch answers a different question from a mean over time.
One transformation handles independence; another handles dependency
vmap transforms a scalar simulation into an ensemble operation. scan still enforces the sequential state dependence inside each trajectory. Reversing the composition is possible here: the carry can hold all three independent states, giving a time-major result of shape . Its transpose matches the first construction. If one trajectory exchanges heat with another, the batch members no longer obey independent scalar equations; write a coupled vector state instead.
Use physical structure as a second check
This equation is linear in the initial state. Starting at must produce four times the trajectory starting at . That check is separate from the exponential comparison and catches unintended normalization over the batch axis. Linearity is special to this model; do not impose it on a nonlinear reaction model simply because batching worked here.
Choose saved outputs deliberately
Saving every state costs storage proportional to batch size times number of saved times. Some objectives need only the final state. In that case return no saved observation from scan and keep its final carry. This reduces the explicit output size; it does not by itself establish the memory cost of reverse-mode differentiation, which may retain or recompute intermediates.
Batching preserves independent physical trajectories
Predict before looking: Should the highest curve decay proportionally faster, or preserve its ratio to the other curves?
Read the figure
Time in seconds runs horizontally; excess temperature runs vertically. The three curves correspond to initial values , and . Each is one row of the batch-major output, including its initial observation.
At two seconds their values are approximately , and . Their absolute changes differ, but every curve retains the same fraction of its initial value. The highest remains four times the lowest throughout.
Connect it to the computation
The common rate produces that shared relative decay. vmap adds independent experiments without inserting a mean, normalization or interaction between them. The code checks both this proportional relationship and the analytic exponential.
The plot has no runtime or memory axis. It establishes numerical behavior for this ensemble, not a speedup from vectorization. The last lesson adds synchronized measurements with their own limitations.
Open full-size figureDownload data and provenance
The notebook contains the data experiment, plotting code, and recorded figure output. Rerun it to test your changes.
Where to put & run this code: Work in phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.py (or downloaded exercises/science-02.py / exercises/science-02.ipynb) and execute from the repository root with python3 phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.py.
1 Use a higher-order scalar transition
Append this block to main.py in your CPU course environment; for the first block create the file. Run blocks in order.
# Step 1 — Use a higher-order scalar transition: Runge–Kutta uses four slopes inside one step.
import jax
# Update state in place with the new values.
jax.config.update("jax_enable_x64", True)
import jax.numpy as jnp
import numpy as np

def rk4_step(rate, value, dt):
    a = -rate*value
    b = -rate*(value + dt*a/2)
    c = -rate*(value + dt*b/2)
    d = -rate*(value + dt*c)
    return value + dt*(a + 2*b + 2*c + d)/6

# Define `solve(rate, initial, steps, dt)` to carry state across steps with `jax.lax.scan`:
def solve(rate, initial, steps=40, dt=0.05):
    def advance(value, unused):
        next_value = rk4_step(rate, value, dt)
        return next_value, next_value
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, initial, None, length=steps)
    return jnp.concatenate((jnp.atleast_1d(initial), tail))
Code building blocks in this step
jax.lax.scan(step_fn, init_carry, xs, length=...)— Compiles a sequential loop wherestep_fn(carry, x)returns(next_carry, y), returning(final_carry, stacked_ys).
Runge–Kutta uses four slopes inside one step. It remains a pure transition, so the same scan interface can save its trajectory.
2 Batch initial conditions while sharing the model
Append this block to main.py in your CPU course environment; for the first block create the file. Run blocks in order.
# Step 2 — Batch initial conditions while sharing the model: The batch axis is independent initial conditions, not time.
initials = jnp.array([0.5, 1.0, 2.0])
rate, dt, steps = 0.7, 0.05, 40
# Vectorize across the batch dimension with `jax.vmap` (`simulate_batch`).
simulate_batch = jax.jit(jax.vmap(lambda initial: solve(rate, initial, steps, dt)))
trajectories = simulate_batch(initials)
times = np.arange(steps+1)*dt
# Convert `oracle` to a host NumPy array for inspection or verification.
oracle = np.asarray(initials)[:,None]*np.exp(-rate*times[None,:])
# Check tensor shape invariant: `trajectories.shape == (3, 41)`
assert trajectories.shape == (3, 41)
np.testing.assert_allclose(trajectories, oracle, rtol=3e-8, atol=1e-10)
# Convert `` to a host NumPy array for inspection or verification.
np.testing.assert_allclose(np.asarray(trajectories)[2], 4*np.asarray(trajectories)[0], rtol=1e-12)
print("Shape:", trajectories.shape, "endpoints:", np.asarray(trajectories)[:,-1])
Code building blocks in this step
jnp.array(values, dtype=...)— Constructs an immutable device-backed JAX array from Python/NumPy values.jnp.allclose(actual, expected, rtol=..., atol=...)— Checks that two arrays match elementwise within floating-point tolerance.jax.vmap(fn, in_axes=..., out_axes=...)— Vectorizes a single-example function across a batch axis without writing a Python loop.jax.jit(fn) / @jax.jit— Tracesfnwith abstract shapes and compiles a fused XLA executable cached by input shape and dtype.
The batch axis is independent initial conditions, not time. The shared rate and grid are closed over here; vmap adds one leading axis to the scalar solve.
3 Change composition and verify axis meaning
Append this block to main.py in your CPU course environment; for the first block create the file. Run blocks in order.
# Step 3 — Change composition and verify axis meaning: Array arithmetic applies the independent scalar dynamics to all...
# Define `scan_batch(rate, values, steps, dt)` to carry state across steps with `jax.lax.scan`:
def scan_batch(rate, values, steps=40, dt=0.05):
    def advance(state, unused):
        updated = rk4_step(rate, state, dt)
        return updated, updated
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, values, None, length=steps)
    return jnp.concatenate((values[None,:], tail), axis=0)
# Run compiled structured control flow via `jax.lax` (`time_major`).
time_major = scan_batch(rate, initials)
# Check tensor shape invariant: `time_major.shape == (41, 3)`
assert time_major.shape == (41, 3)
np.testing.assert_allclose(time_major.T, trajectories, rtol=1e-12, atol=1e-12)
print("scan(vectors) transposed equals vmap(scan)")
Code building blocks in this step
jnp.allclose(actual, expected, rtol=..., atol=...)— Checks that two arrays match elementwise within floating-point tolerance.jax.lax.scan(step_fn, init_carry, xs, length=...)— Compiles a sequential loop wherestep_fn(carry, x)returns(next_carry, y), returning(final_carry, stacked_ys).
Array arithmetic applies the independent scalar dynamics to all initial conditions. This equivalence would fail if the model coupled different batch members.
View the cumulative build in main.py
These blocks append in order to the same file.
# Step 1 — Use a higher-order scalar transition: Runge–Kutta uses four slopes inside one step.
import jax
# Update state in place with the new values.
jax.config.update("jax_enable_x64", True)
import jax.numpy as jnp
import numpy as np

def rk4_step(rate, value, dt):
    a = -rate*value
    b = -rate*(value + dt*a/2)
    c = -rate*(value + dt*b/2)
    d = -rate*(value + dt*c)
    return value + dt*(a + 2*b + 2*c + d)/6

# Define `solve(rate, initial, steps, dt)` to carry state across steps with `jax.lax.scan`:
def solve(rate, initial, steps=40, dt=0.05):
    def advance(value, unused):
        next_value = rk4_step(rate, value, dt)
        return next_value, next_value
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, initial, None, length=steps)
    return jnp.concatenate((jnp.atleast_1d(initial), tail))

# Step 2 — Batch initial conditions while sharing the model: The batch axis is independent initial conditions, not time.
initials = jnp.array([0.5, 1.0, 2.0])
rate, dt, steps = 0.7, 0.05, 40
# Vectorize across the batch dimension with `jax.vmap` (`simulate_batch`).
simulate_batch = jax.jit(jax.vmap(lambda initial: solve(rate, initial, steps, dt)))
trajectories = simulate_batch(initials)
times = np.arange(steps+1)*dt
# Convert `oracle` to a host NumPy array for inspection or verification.
oracle = np.asarray(initials)[:,None]*np.exp(-rate*times[None,:])
# Check tensor shape invariant: `trajectories.shape == (3, 41)`
assert trajectories.shape == (3, 41)
np.testing.assert_allclose(trajectories, oracle, rtol=3e-8, atol=1e-10)
# Convert `` to a host NumPy array for inspection or verification.
np.testing.assert_allclose(np.asarray(trajectories)[2], 4*np.asarray(trajectories)[0], rtol=1e-12)
print("Shape:", trajectories.shape, "endpoints:", np.asarray(trajectories)[:,-1])

# Step 3 — Change composition and verify axis meaning: Array arithmetic applies the independent scalar dynamics to all...
# Define `scan_batch(rate, values, steps, dt)` to carry state across steps with `jax.lax.scan`:
def scan_batch(rate, values, steps=40, dt=0.05):
    def advance(state, unused):
        updated = rk4_step(rate, state, dt)
        return updated, updated
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, values, None, length=steps)
    return jnp.concatenate((values[None,:], tail), axis=0)
# Run compiled structured control flow via `jax.lax` (`time_major`).
time_major = scan_batch(rate, initials)
# Check tensor shape invariant: `time_major.shape == (41, 3)`
assert time_major.shape == (41, 3)
np.testing.assert_allclose(time_major.T, trajectories, rtol=1e-12, atol=1e-12)
print("scan(vectors) transposed equals vmap(scan)")
Run the example
python3 phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.pyAbout this command
This shortcut uses an activated macOS/Linux course environment in the repository folder. For Windows, use the explicit interpreter command in “Setup help” above. The script includes worked examples and reference solutions.
Inspect the complete assembled example
# Step 1 — Use a higher-order scalar transition: Runge–Kutta uses four slopes inside one step.
import jax
# Update state in place with the new values.
jax.config.update("jax_enable_x64", True)
import jax.numpy as jnp
import numpy as np

def rk4_step(rate, value, dt):
    a = -rate*value
    b = -rate*(value + dt*a/2)
    c = -rate*(value + dt*b/2)
    d = -rate*(value + dt*c)
    return value + dt*(a + 2*b + 2*c + d)/6

# Define `solve(rate, initial, steps, dt)` to carry state across steps with `jax.lax.scan`:
def solve(rate, initial, steps=40, dt=0.05):
    def advance(value, unused):
        next_value = rk4_step(rate, value, dt)
        return next_value, next_value
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, initial, None, length=steps)
    return jnp.concatenate((jnp.atleast_1d(initial), tail))

# Step 2 — Batch initial conditions while sharing the model: The batch axis is independent initial conditions, not time.
initials = jnp.array([0.5, 1.0, 2.0])
rate, dt, steps = 0.7, 0.05, 40
# Vectorize across the batch dimension with `jax.vmap` (`simulate_batch`).
simulate_batch = jax.jit(jax.vmap(lambda initial: solve(rate, initial, steps, dt)))
trajectories = simulate_batch(initials)
times = np.arange(steps+1)*dt
# Convert `oracle` to a host NumPy array for inspection or verification.
oracle = np.asarray(initials)[:,None]*np.exp(-rate*times[None,:])
# Check tensor shape invariant: `trajectories.shape == (3, 41)`
assert trajectories.shape == (3, 41)
np.testing.assert_allclose(trajectories, oracle, rtol=3e-8, atol=1e-10)
# Convert `` to a host NumPy array for inspection or verification.
np.testing.assert_allclose(np.asarray(trajectories)[2], 4*np.asarray(trajectories)[0], rtol=1e-12)
print("Shape:", trajectories.shape, "endpoints:", np.asarray(trajectories)[:,-1])

# Step 3 — Change composition and verify axis meaning: Array arithmetic applies the independent scalar dynamics to all...
# Define `scan_batch(rate, values, steps, dt)` to carry state across steps with `jax.lax.scan`:
def scan_batch(rate, values, steps=40, dt=0.05):
    def advance(state, unused):
        updated = rk4_step(rate, state, dt)
        return updated, updated
    # Run compiled structured control flow via `jax.lax` (`(_, tail)`).
    _, tail = jax.lax.scan(advance, values, None, length=steps)
    return jnp.concatenate((values[None,:], tail), axis=0)
# Run compiled structured control flow via `jax.lax` (`time_major`).
time_major = scan_batch(rate, initials)
# Check tensor shape invariant: `time_major.shape == (41, 3)`
assert time_major.shape == (41, 3)
np.testing.assert_allclose(time_major.T, trajectories, rtol=1e-12, atol=1e-12)
print("scan(vectors) transposed equals vmap(scan)")
Expected result: Shape (3, 41); endpoints approximately [0.12329849, 0.24659697, 0.49319394]. Both compositions agree.
Recorded reference execution
Reference output captured from executing the complete lesson script (code/main.py) and its assertions in the course CPU environment.
Shape: (3, 41) endpoints: [0.12329848 0.24659697 0.49319394]
scan(vectors) transposed equals vmap(scan)
Shape: (3, 41) endpoints: [0.12329848 0.24659697 0.49319394]
scan(vectors) transposed equals vmap(scan)
RK4 polynomial maximum difference: 1.4432899320127035e-15
Paired-rate endpoints: [0.33516002 0.24659697 0.22160636]
Permutation preserves trajectory identity
Only final states returned: [0.12329848 0.24659697 0.49319394]
Grid axes: rate, initial condition, time (3, 3, 41)
PASS: science-02
Download execution record · The notebook includes executed cells and figure outputs. Compare your run with these values; timings depend on the machine.
Compare RK4 with an independent polynomial
# Experiment — Compare RK4 with an independent polynomial: This checks the discrete algorithm independently of the...
z = -rate*dt
multiplier = 1 + z + z*z/2 + z**3/6 + z**4/24
polynomial = np.asarray(initials)[:,None]*multiplier**np.arange(steps+1)[None,:]
np.testing.assert_allclose(trajectories, polynomial, rtol=1e-12, atol=1e-12)
print("RK4 polynomial maximum difference:", np.max(np.abs(np.asarray(trajectories)-polynomial)))
Expected: Differences are near float64 roundoff.
This checks the discrete algorithm independently of the continuous exponential. RK4 has much smaller error here but is not exact.
Let each trajectory have its own rate
# Experiment — Let each trajectory have its own rate: Mapping both axes pairs corresponding entries.
rates = jnp.array([0.2, 0.7, 1.1])
# Vectorize across the batch dimension with `jax.vmap` (`paired`).
paired = jax.vmap(lambda k, u: solve(k,u), in_axes=(0,0))(rates,initials)
# Convert `paired_reference` to a host NumPy array for inspection or verification.
paired_reference = np.asarray(initials)[:,None]*np.exp(-np.asarray(rates)[:,None]*times)
np.testing.assert_allclose(paired,paired_reference,rtol=2e-7,atol=1e-10)
print("Paired-rate endpoints:", np.asarray(paired)[:,-1])
Expected: Three trajectories now have different relative decay rates.
Mapping both axes pairs corresponding entries. A grid of every rate with every initial value would require nested mapping and a different output contract.
Make it yours
Where to put your code: Append your solution at the bottom of phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.py (or inside the Make it yours cell of exercises/science-02.ipynb) and run python3 phases/10-science/02-vectorize-trajectories-and-scan-time/code/main.py to verify your prediction before opening the reference solution.
Add a fourth initial condition, verify the changed output shape and exponential values, then verify that reordering initial conditions reorders rows only.
Show a writing guide and starter scaffold
How to write this exercise code: step-by-step recipe & starter scaffold
1. Key functions & syntax to use:
jnp.array(values, dtype=...)— Constructs an immutable device-backed JAX array from Python/NumPy values.jnp.allclose(actual, expected, rtol=..., atol=...)— Checks that two arrays match elementwise within floating-point tolerance.jax.vmap(fn, in_axes=..., out_axes=...)— Vectorizes a single-example function across a batch axis without writing a Python loop.
2. Step-by-step implementation plan:
- Vectorize across the batch dimension with
jax.vmap(changed). - Check tensor shape invariant:
changed.shape == (4,41) - Convert
to a host NumPy array for inspection or verification. - Vectorize across the batch dimension with
jax.vmap(reordered).
# Exercise solution: Add a fourth initial condition, verify the changed output shape and...
changed_initials = jnp.array(...)  # TODO: compute changed_initials
# Vectorize across the batch dimension with `jax.vmap` (`changed`).
changed = jax.vmap(...)  # TODO: compute changed
# Check tensor shape invariant: `changed.shape == (4,41)`
assert changed.shape  # TODO: complete assertion check
# Convert `` to a host NumPy array for inspection or verification.
np.testing.assert_allclose(changed,np.asarray(changed_initials)[:,None]*np.exp(-0.7*times),rtol=3e-8)
order = jnp.array(...)  # TODO: compute order
# Vectorize across the batch dimension with `jax.vmap` (`reordered`).
reordered = jax.vmap(...)  # TODO: compute reordered
np.testing.assert_allclose(reordered,changed[order],rtol = ...  # TODO: compute np.testing.assert_allclose(reordered,changed[order],rtol
print("Permutation preserves trajectory identity")
Reveal the reference solution
# Exercise solution: Add a fourth initial condition, verify the changed output shape and...
changed_initials = jnp.array([0.5, 1.0, 2.0, 3.0])
# Vectorize across the batch dimension with `jax.vmap` (`changed`).
changed = jax.vmap(lambda u: solve(0.7,u))(changed_initials)
# Check tensor shape invariant: `changed.shape == (4,41)`
assert changed.shape == (4,41)
# Convert `` to a host NumPy array for inspection or verification.
np.testing.assert_allclose(changed,np.asarray(changed_initials)[:,None]*np.exp(-0.7*times),rtol=3e-8)
order = jnp.array([3,0,2,1])
# Vectorize across the batch dimension with `jax.vmap` (`reordered`).
reordered = jax.vmap(lambda u: solve(0.7,u))(changed_initials[order])
np.testing.assert_allclose(reordered,changed[order],rtol=1e-12)
print("Permutation preserves trajectory identity")
Save only what the objective needs
Practice
Implement a final-state-only solve and compare it with the final column of the saved batch. Explain which allocation was removed.
Show a writing guide and starter scaffold
How to write this practice solution: step-by-step recipe & starter scaffold
1. Key functions & syntax to use:
jnp.allclose(actual, expected, rtol=..., atol=...)— Checks that two arrays match elementwise within floating-point tolerance.jax.vmap(fn, in_axes=..., out_axes=...)— Vectorizes a single-example function across a batch axis without writing a Python loop.jax.lax.scan(step_fn, init_carry, xs, length=...)— Compiles a sequential loop wherestep_fn(carry, x)returns(next_carry, y), returning(final_carry, stacked_ys).
2. Step-by-step implementation plan:
- Define
final_only(rate, initial, steps, dt)to carry state across steps withjax.lax.scan: - Vectorize across the batch dimension with
jax.vmap(finals).
# Save only what the objective needs (Practice): The explicit trajectory output is removed.
# Define `final_only(rate, initial, steps, dt)` to carry state across steps with `jax.lax.scan`:
def final_only(rate, initial, steps=40, dt=0.05):
    def advance(value, unused):
        return ...  # TODO: return computed result
    return jax.lax.scan(advance,initial,None,length = ...  # TODO: compute return jax.lax.scan(advance,initial,None,length
# Vectorize across the batch dimension with `jax.vmap` (`finals`).
finals = jax.vmap(...)  # TODO: compute finals
np.testing.assert_allclose(finals,trajectories[:,-1],rtol=1e-12)
print("Only final states returned:", np.asarray(finals))
Show a hint
scan may emit None while its carry still advances.
Reveal reference solution and reasoning
# Save only what the objective needs (Practice): The explicit trajectory output is removed.
# Define `final_only(rate, initial, steps, dt)` to carry state across steps with `jax.lax.scan`:
def final_only(rate, initial, steps=40, dt=0.05):
    def advance(value, unused):
        return rk4_step(rate,value,dt), None
    return jax.lax.scan(advance,initial,None,length=steps)[0]
# Vectorize across the batch dimension with `jax.vmap` (`finals`).
finals = jax.vmap(lambda u: final_only(0.7,u))(initials)
np.testing.assert_allclose(finals,trajectories[:,-1],rtol=1e-12)
print("Only final states returned:", np.asarray(finals))
The explicit trajectory output is removed. Differentiation memory requires separate analysis and measurement.
Pairing versus Cartesian products
Challenge
Build the full grid of three rates and three initial values. Show that its diagonal agrees with the paired-rate experiment.
Show a writing guide and starter scaffold
How to write this practice solution: step-by-step recipe & starter scaffold
1. Key functions & syntax to use:
jnp.arange(n, dtype=...)— Creates a 1-D JAX array of evenly spaced values[0, 1, ..., n-1]on the target device.jnp.allclose(actual, expected, rtol=..., atol=...)— Checks that two arrays match elementwise within floating-point tolerance.jax.vmap(fn, in_axes=..., out_axes=...)— Vectorizes a single-example function across a batch axis without writing a Python loop.
2. Step-by-step implementation plan:
- Vectorize across the batch dimension with
jax.vmap(grid). - Check tensor shape invariant:
grid.shape == (3,3,41) - Create evenly spaced index values in
.
# Pairing versus Cartesian products (Challenge): Paired batches and Cartesian products are different experiments.
# Vectorize across the batch dimension with `jax.vmap` (`grid`).
grid = jax.vmap(...)  # TODO: compute grid
# Check tensor shape invariant: `grid.shape == (3,3,41)`
assert grid.shape  # TODO: complete assertion check
# Create evenly spaced index values in ``.
np.testing.assert_allclose(grid[jnp.arange(3),jnp.arange(3)],paired,rtol = ...  # TODO: compute np.testing.assert_allclose(grid[jnp.arange(3),jnp.arange(3)],paired,rtol
print("Grid axes: rate, initial condition, time", grid.shape)
Show a hint
Use nested vmap; identify the rate, initial-condition and time axes explicitly.
Reveal reference solution and reasoning
# Pairing versus Cartesian products (Challenge): Paired batches and Cartesian products are different experiments.
# Vectorize across the batch dimension with `jax.vmap` (`grid`).
grid = jax.vmap(lambda k: jax.vmap(lambda u: solve(k,u))(initials))(rates)
# Check tensor shape invariant: `grid.shape == (3,3,41)`
assert grid.shape == (3,3,41)
# Create evenly spaced index values in ``.
np.testing.assert_allclose(grid[jnp.arange(3),jnp.arange(3)],paired,rtol=1e-12)
print("Grid axes: rate, initial condition, time", grid.shape)
Paired batches and Cartesian products are different experiments. The diagonal correspondence verifies the axis interpretation.
Diagnose the result
If the reference comparison broadcasts unexpectedly, print both shapes before reducing anything. Compare a named row and a named time column. If changing one initial condition changes other rows, inspect reductions or coupling across the batch. A reduction can hide an axis error while still producing a plausible scalar.
Carry forward
- Improve one step before multiplying trajectories
- Read shapes as physical statements
- One transformation handles independence; another handles dependency
- Use physical structure as a second check
- Choose saved outputs deliberately
Keep your evidence
Polynomial/exponential references, batch/time shape diagram, permutation and final-only checks. Keep the environment, observed outputs and your explanation of the figure.
Save your modified code, its output, and an explanation of your prediction. Checkpoint answers and exercise evidence are tracked separately.
Saved in this browser. Export or back up your portfolio anytime in My learning.
Verified on local CPU. Stage to a Cloud TPU VM via Cloud TPU setup to record accelerator execution receipts (TODO: add automated Cloud TPU CI execution receipts).